Visual Tracking Under Real Constraints
Integrated vision, calibration, and feedback control into a laser-tracking prototype with sub-centimeter error in the reported tests. Guangdong Second Prize.
Closing the Loop from Pixels to Motion
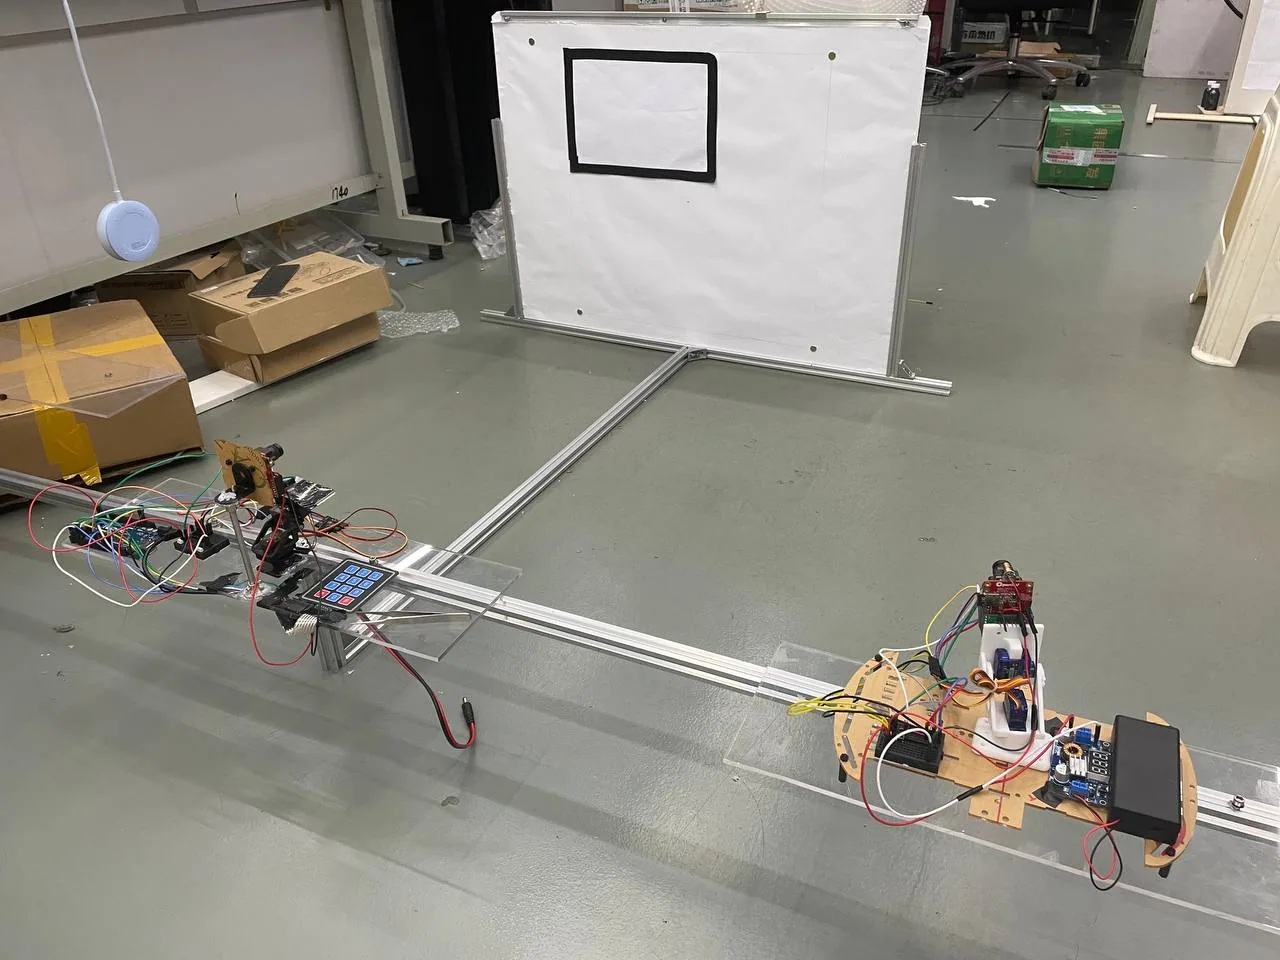
Our Guangdong Second Prize entry in the 2023 National Undergraduate Electronic Design Contest used two servo-driven gimbals for vision-guided laser tracking. I implemented image processing, Kalman filtering, and PID control, then tuned the integrated system during the four-day competition.
OpenMV detected laser spots; an Arduino Mega2560 converted image coordinates into actuator commands. Regression-based calibration addressed geometric bias, while filtering and trajectory interpolation reduced noise-driven motion.
Performance on the Demonstration Tasks
The reported static and dynamic positioning tests achieved less than 1 cm error, with 0.5–0.6 seconds from target detection to stable tracking lock. Exposure tuning, LAB color filtering, and servo calibration helped sustain the complete detection-to-control loop under the competition conditions.