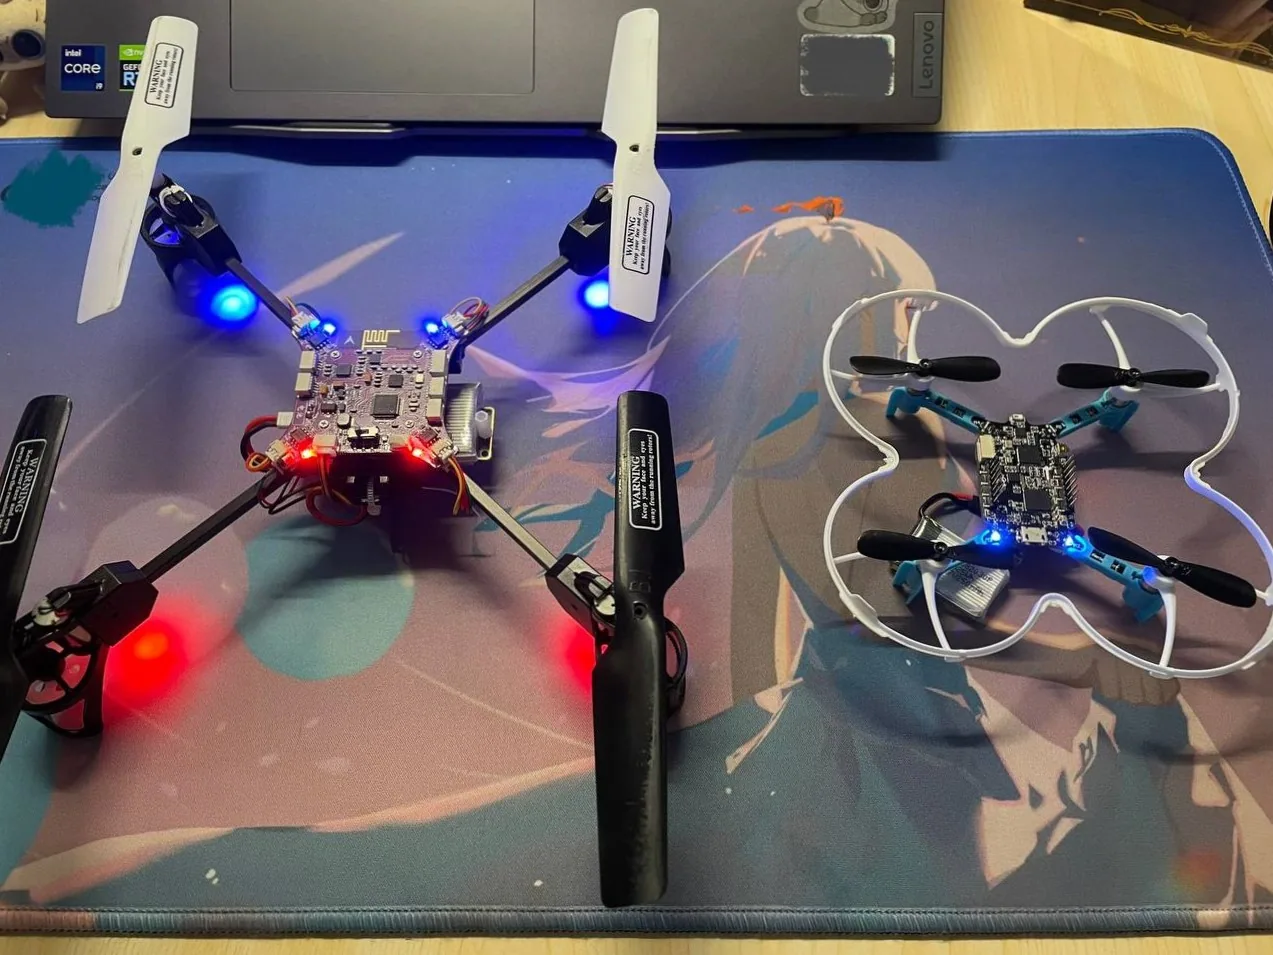
Coordinated Quadcopters
Linked wireless state exchange with onboard flight control to demonstrate coordinated motion between two quadcopters. Third Prize.
Coordinating Two Flying Platforms
I worked on a dual-quadcopter prototype that linked wireless state exchange with onboard flight control. STM32F4 and Nordic devices handled control and communication, while inertial and altitude sensors supplied feedback for PID stabilization.
FreeRTOS separated sensing, communication, and control tasks. Bidirectional messages coordinated the primary and secondary vehicles, with filtering and parameter tuning addressing differences in their dynamics.
From Subsystems to Coordinated Flight
The prototype demonstrated motion matching, and controlled wireless-link tests reached distances of up to 100 meters. Integrating the communication loop with flight control was the main systems challenge: a functioning radio link alone was not sufficient for coordinated motion.
The project received Third Prize in the National Undergraduate Embedded Chip and System Design Competition.