Autonomous Medicine Delivery
Integrated room-number recognition with an autonomous delivery vehicle; expanded training data raised reported recognition accuracy from roughly 80% to over 95%.
Recognizing a Destination and Reaching It
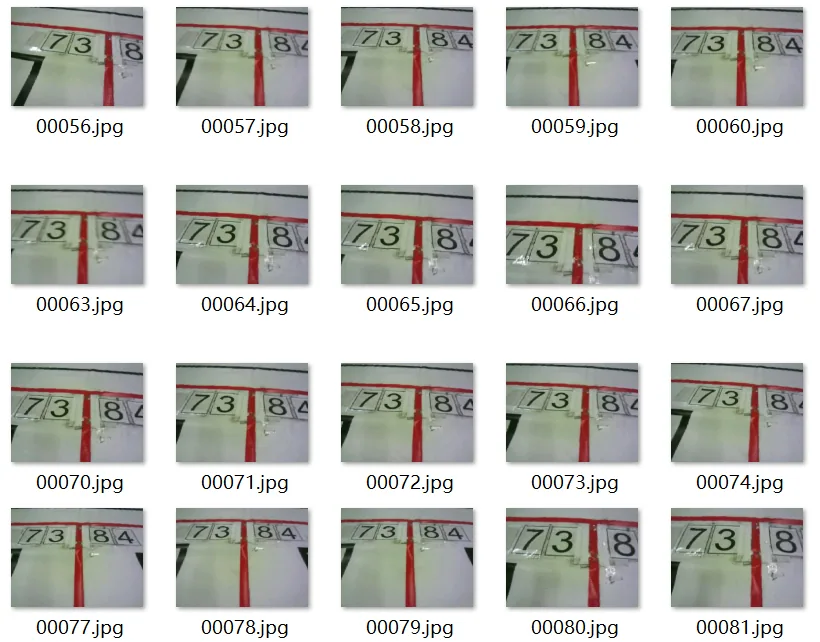
For SUSTech’s electronic design competition, I built the room-number vision system and integrated it with a medicine-delivery vehicle’s tracking and motion controls. The prototype carried a 200 g payload to a designated room and returned to its starting point.
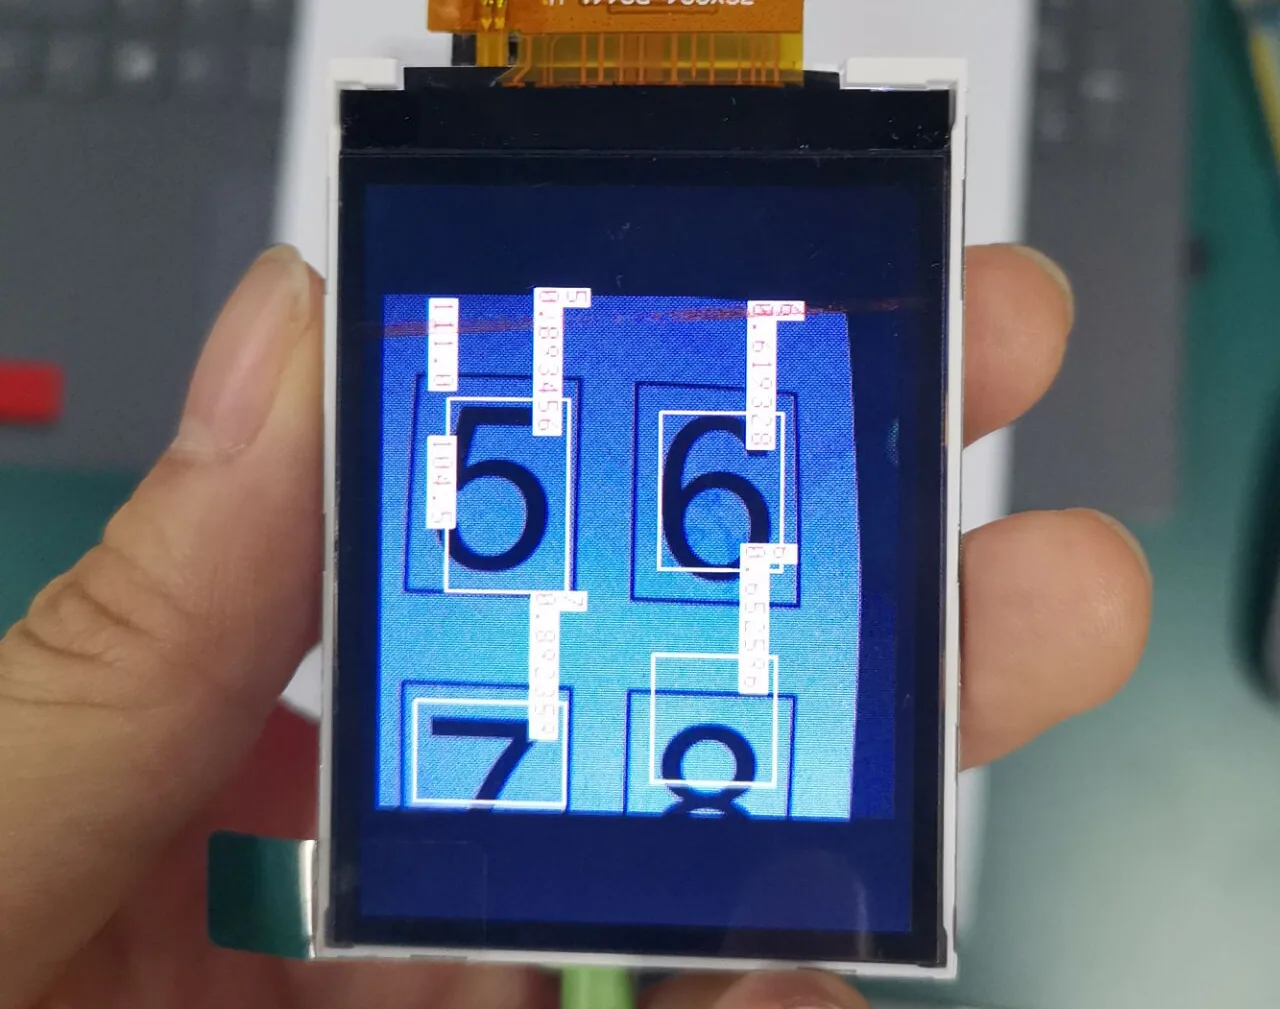
An OpenMV camera handled recognition while an Arduino Mega2560 controlled movement. Switching from grayscale to color sensing resolved unreliable red–white line discrimination, and separate motor control improved turning behavior.
Improving Recognition Through Data
Expanding the room-number dataset to more than 1,000 images and fine-tuning the recognition model raised reported accuracy from approximately 80% to over 95%. The work joined data collection, embedded inference, and control into a complete delivery demonstration.